Objective
Build a mini sumo robot that stays in the ring, finds its opponent and pushes it out.
How it works
Two downward IR sensors detect the white ring edge; when either fires, the bot reverses and turns. An ultrasonic sensor at the front finds the opponent; when it's within 40 cm the bot charges at full power.
Components you'll need
| Component | Qty | Availability | Price | |
|---|---|---|---|---|
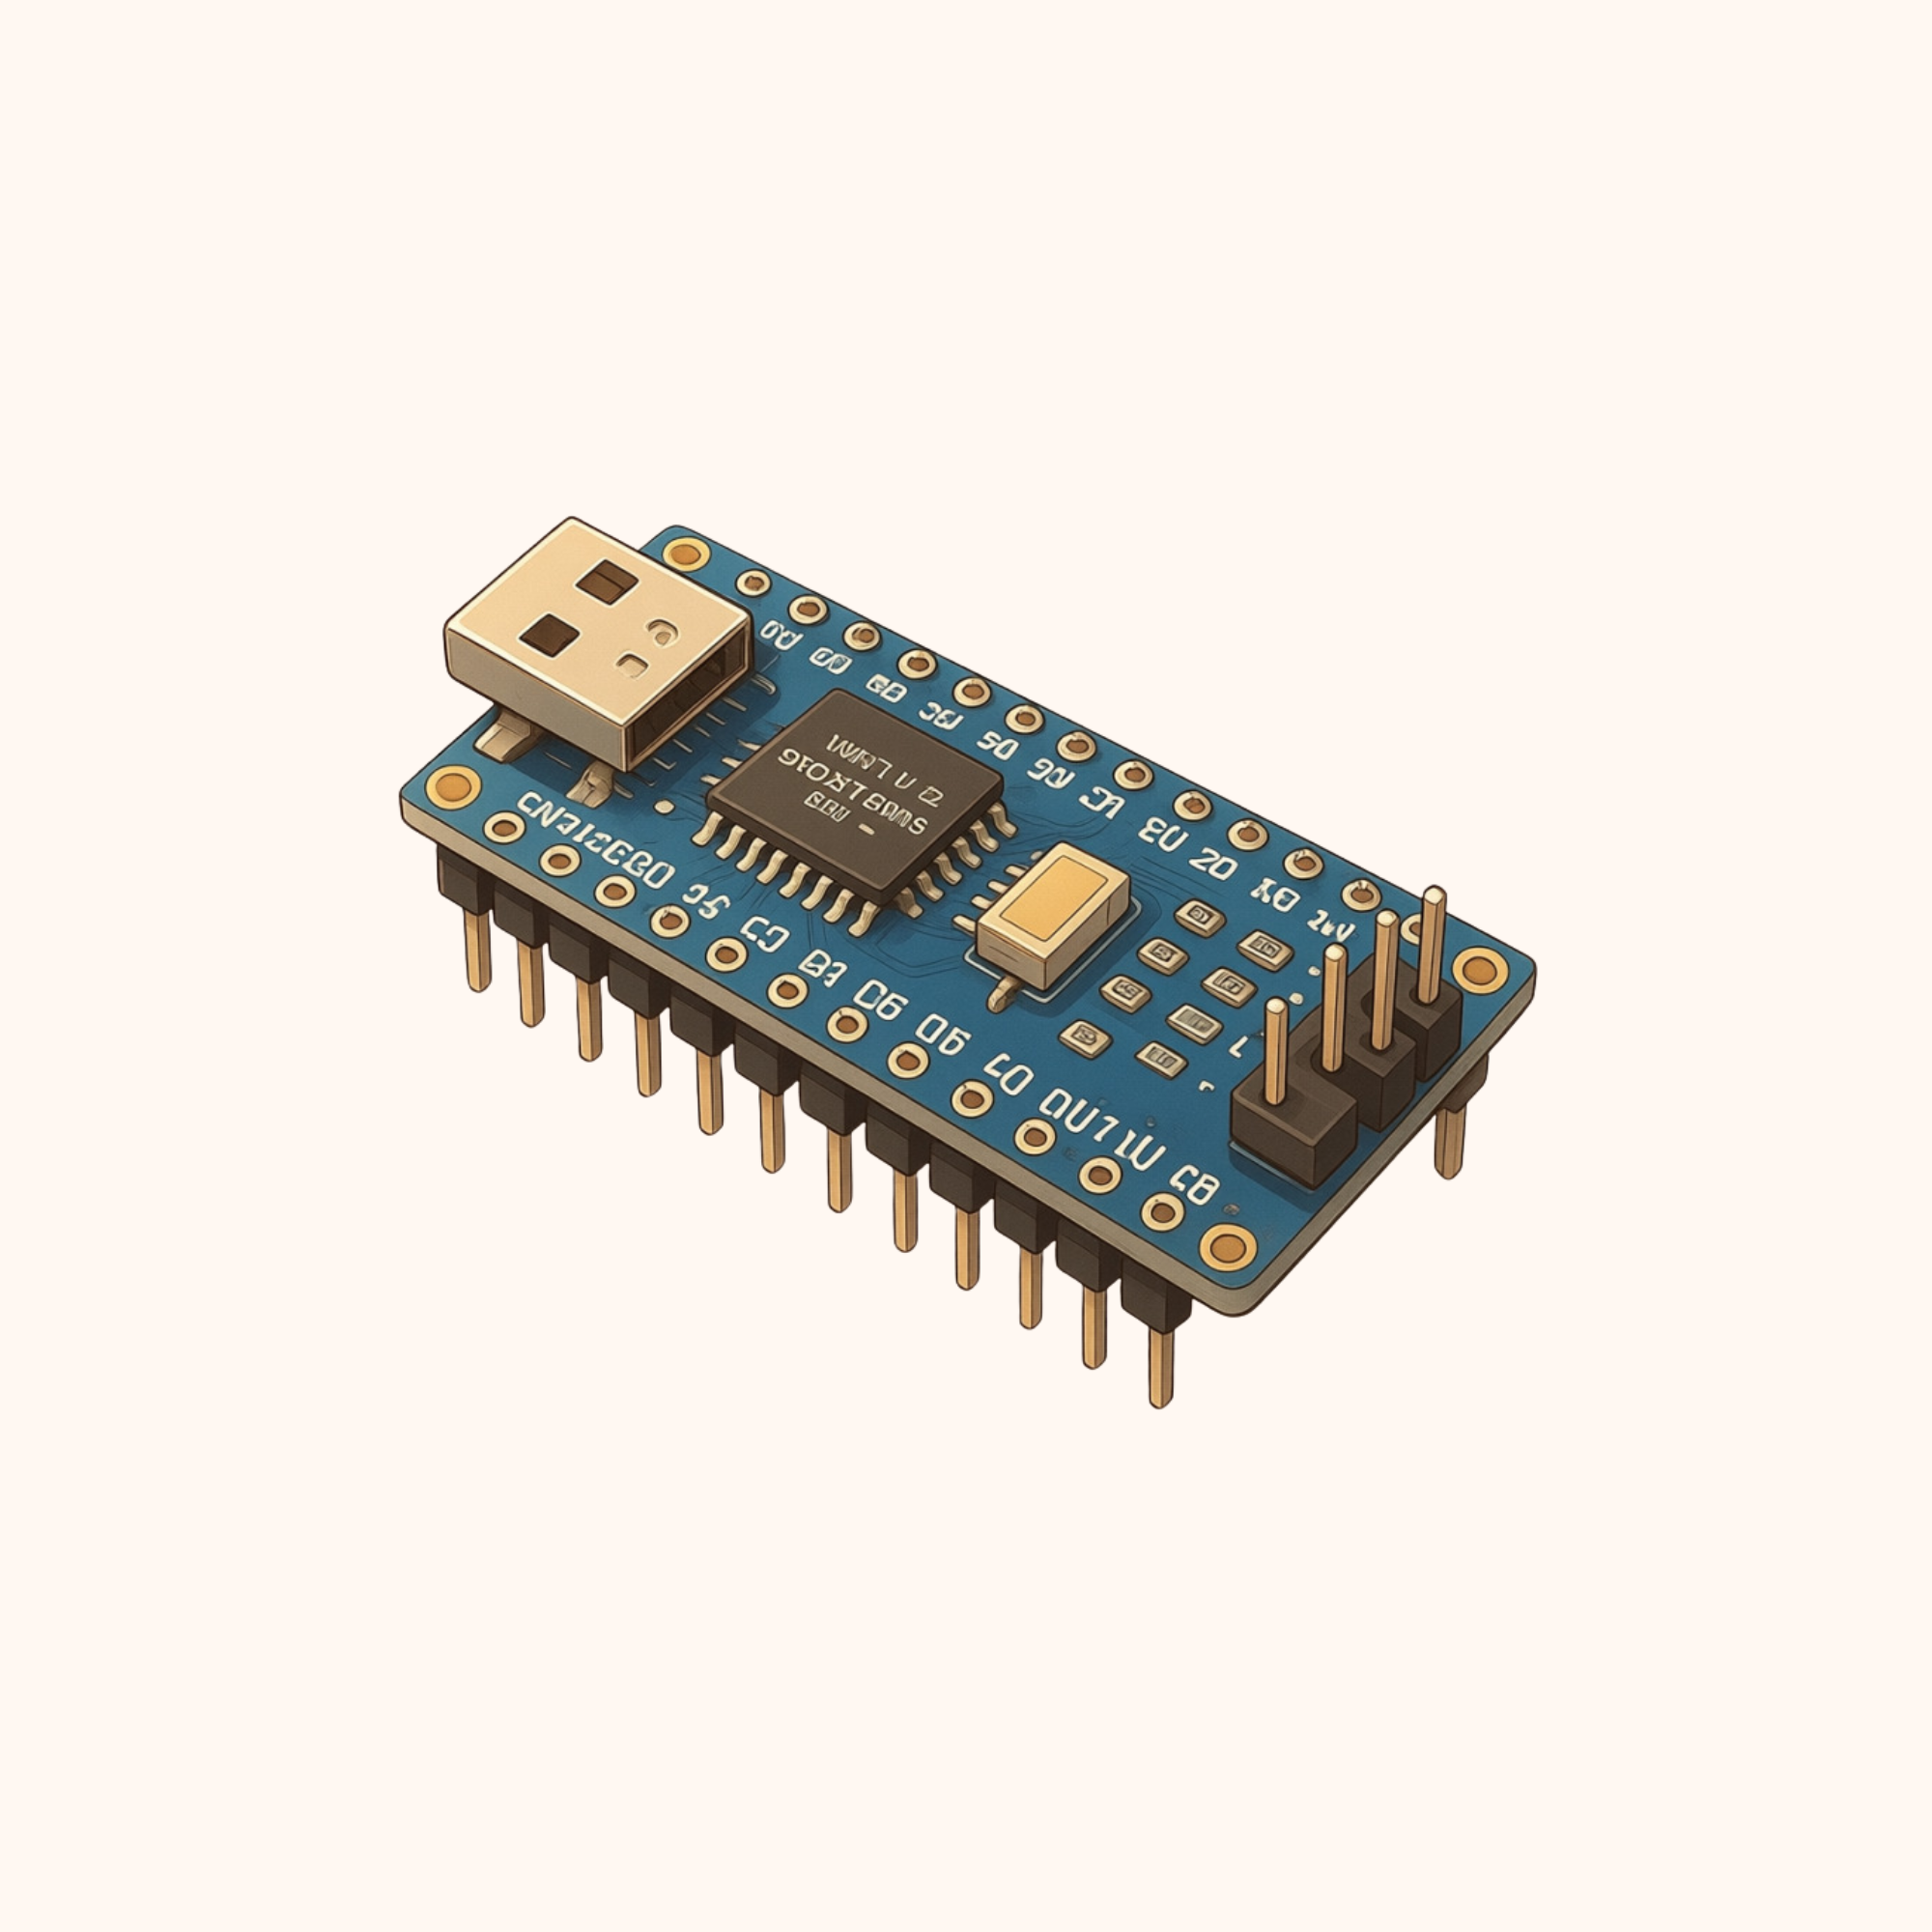 Arduino Nano | ×1 | In stock | $6.17 | |
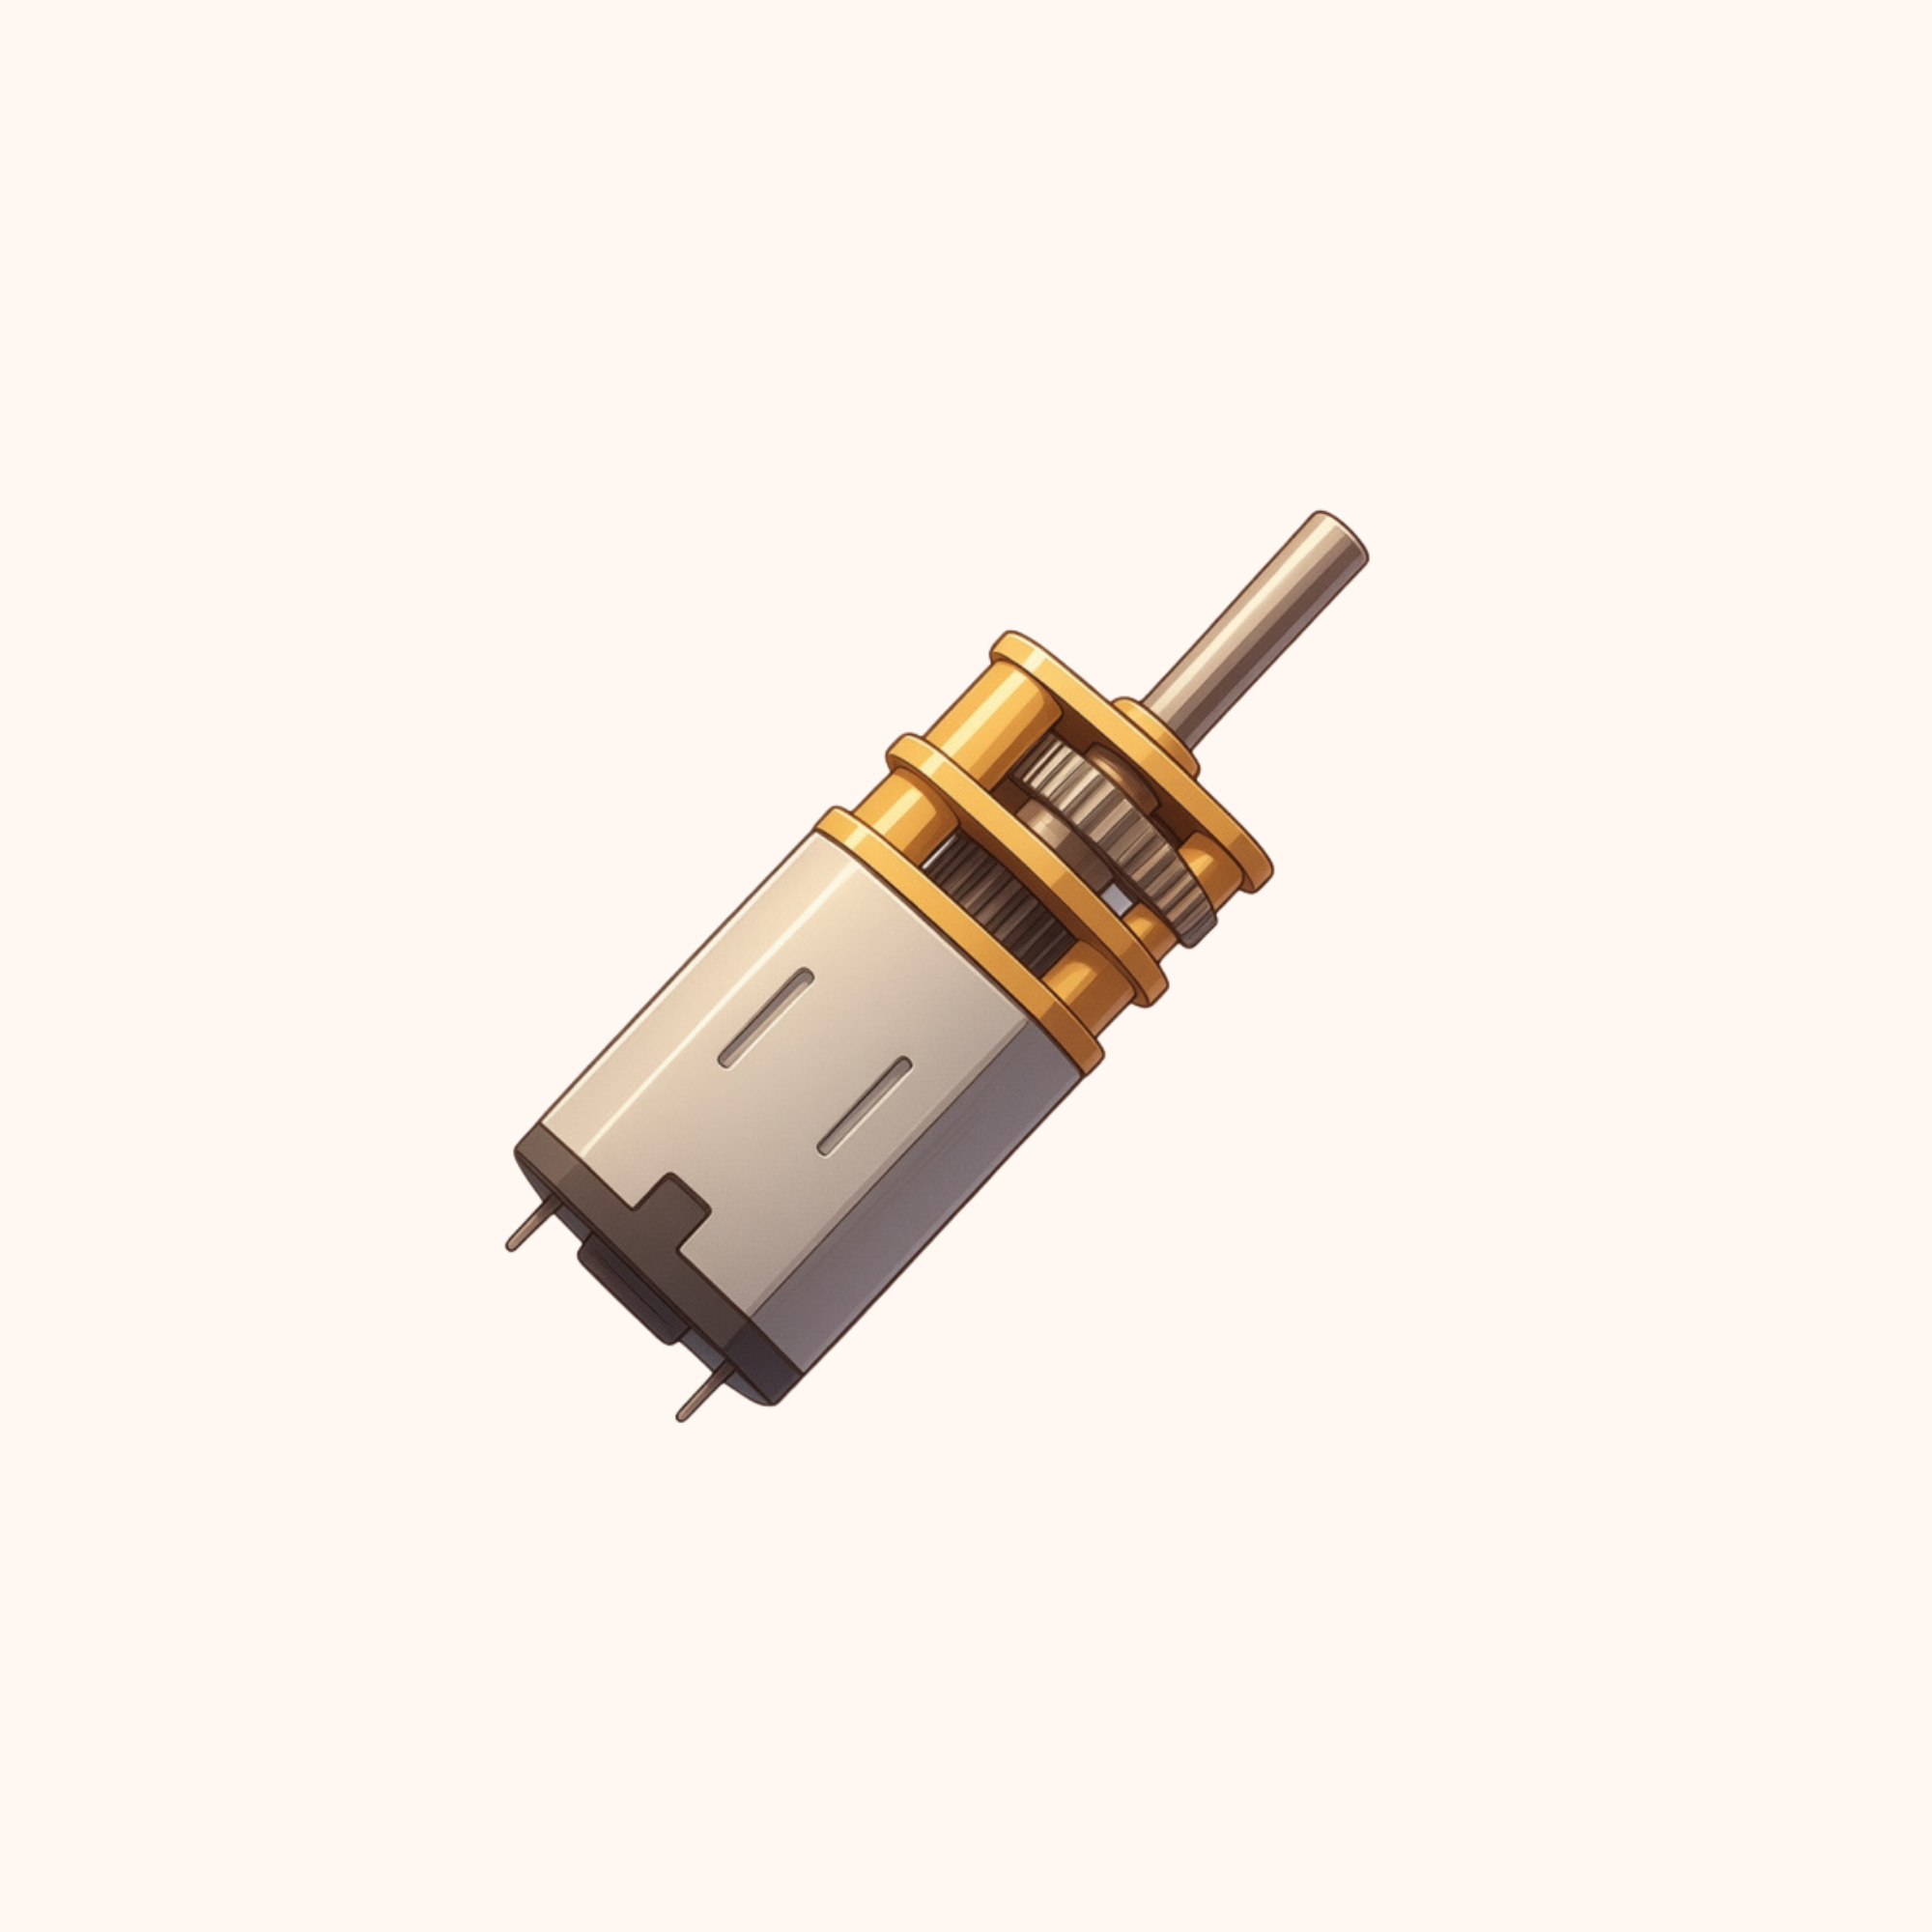 N20 Micro Gear Motor | ×2 | In stock | $4.16 | |
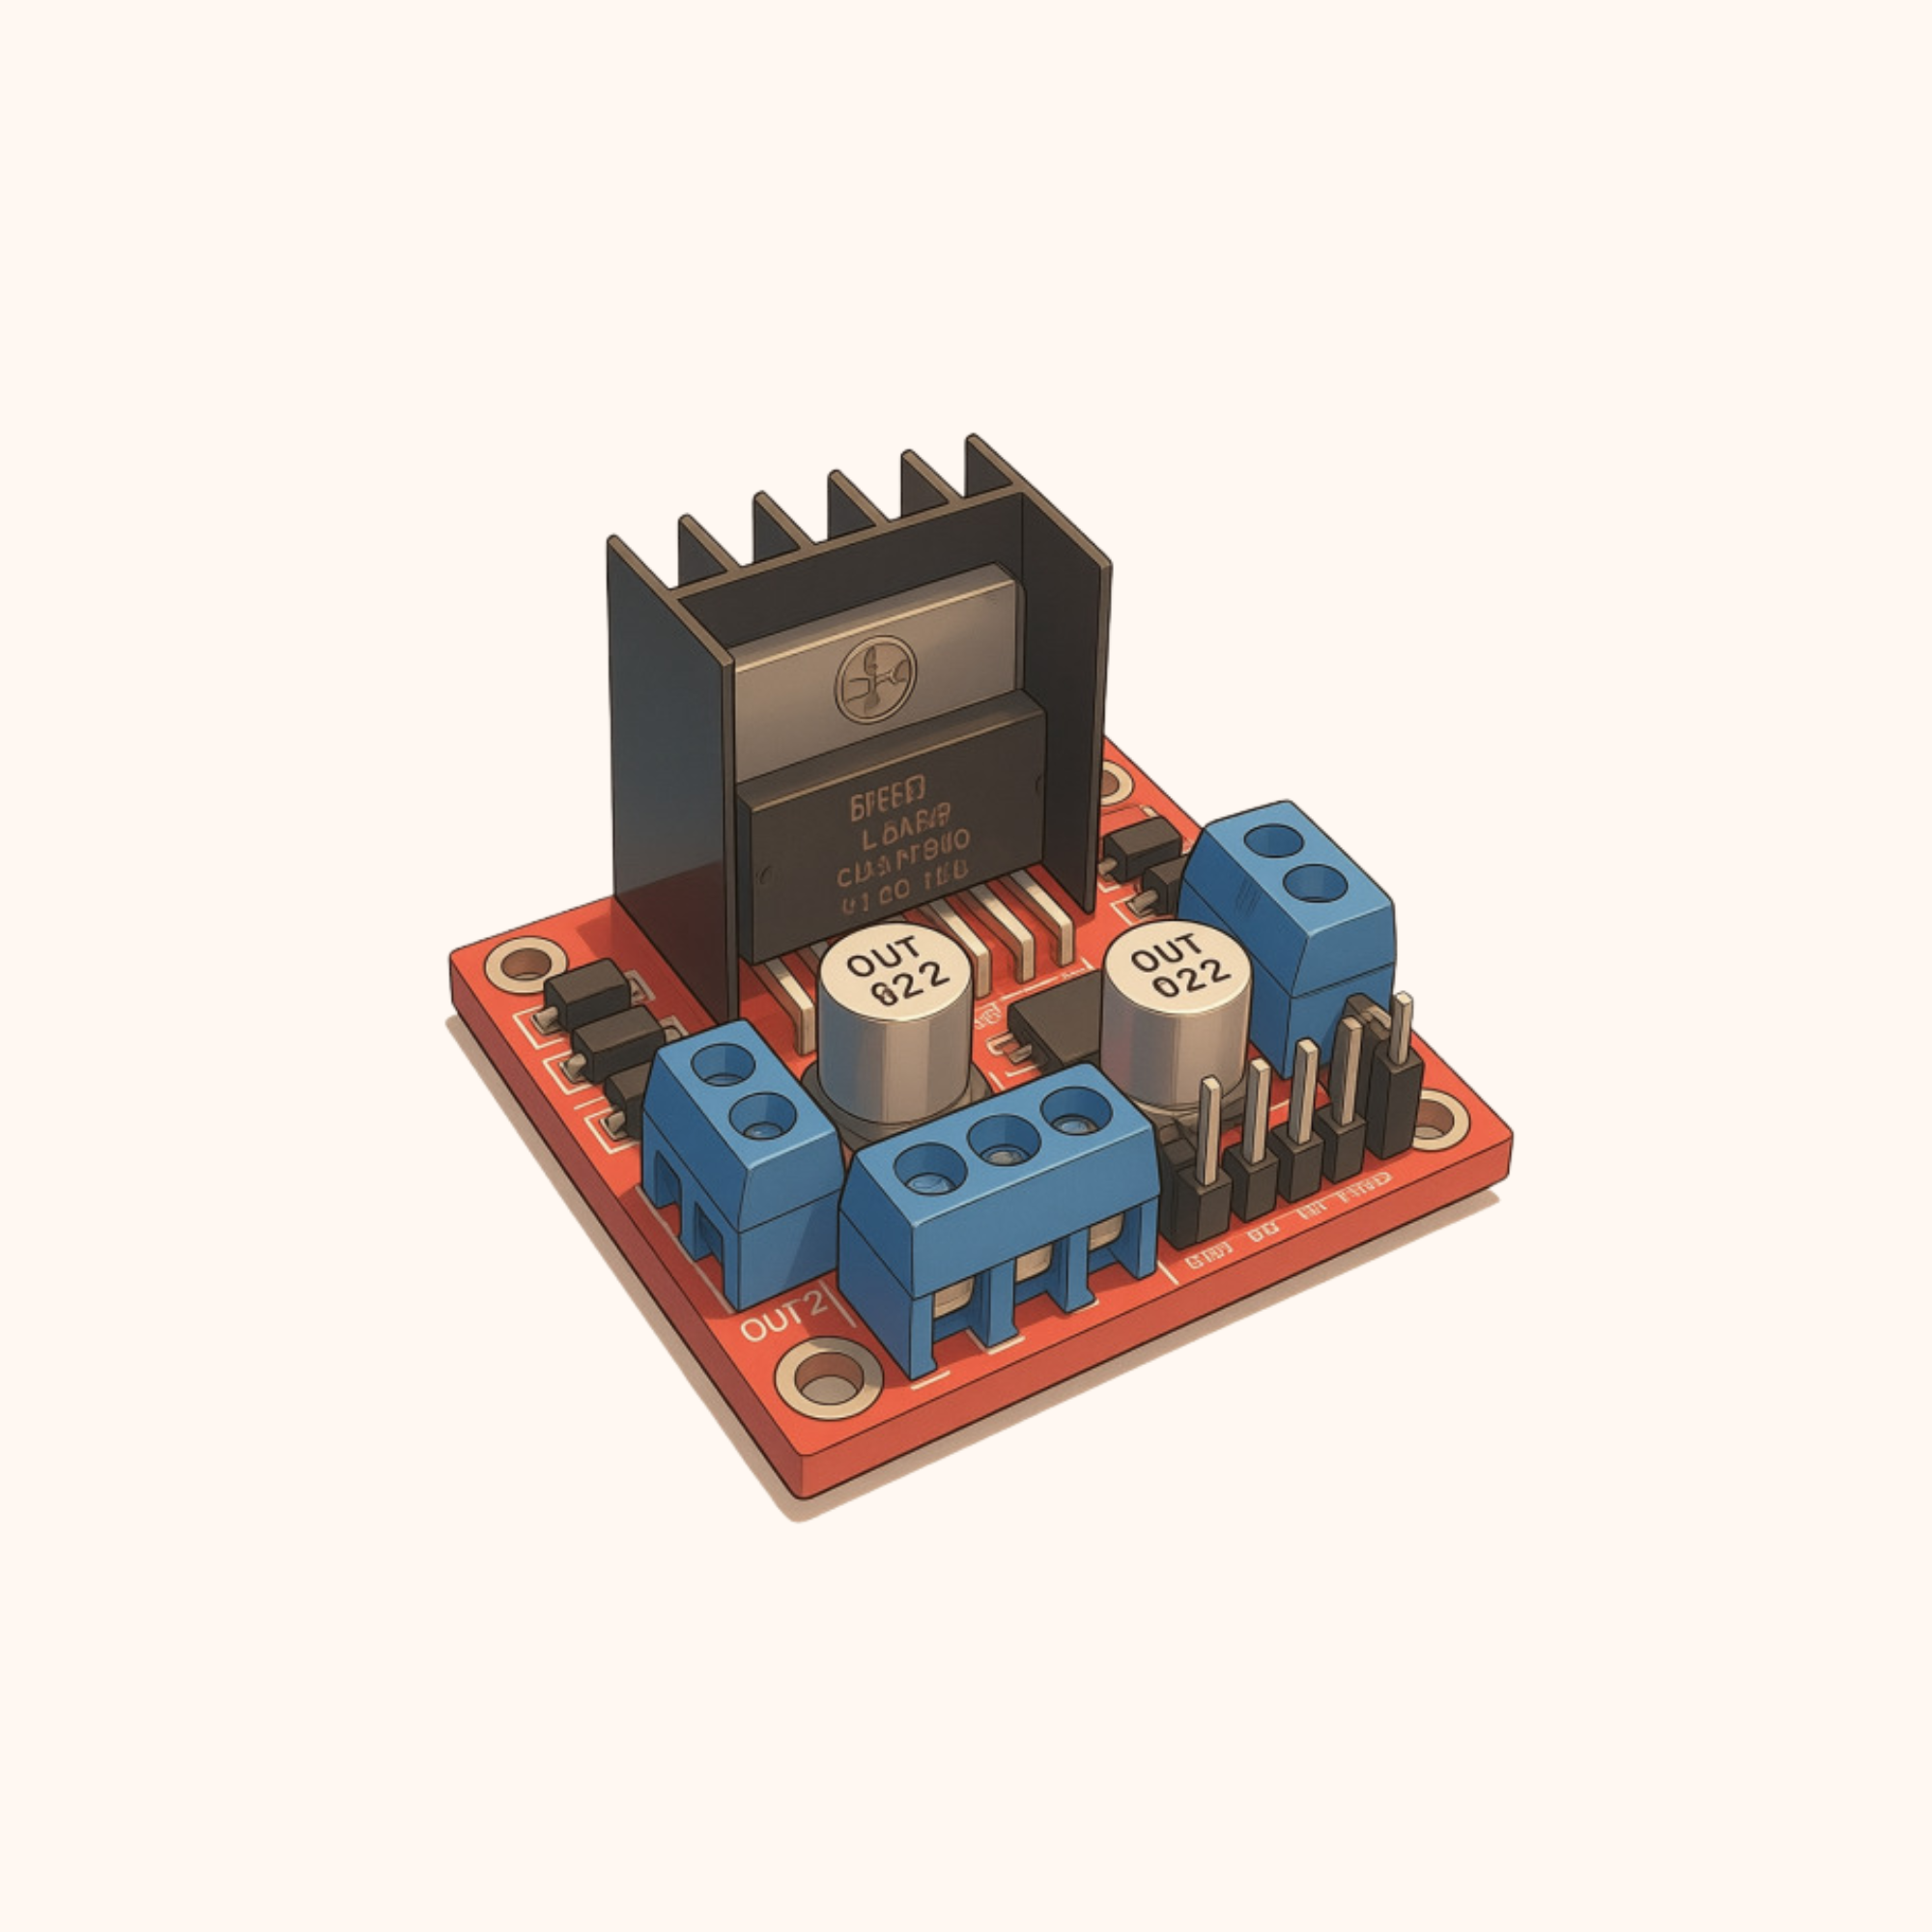 L298N Dual Motor Driver | ×1 | In stock | $2.29 | |
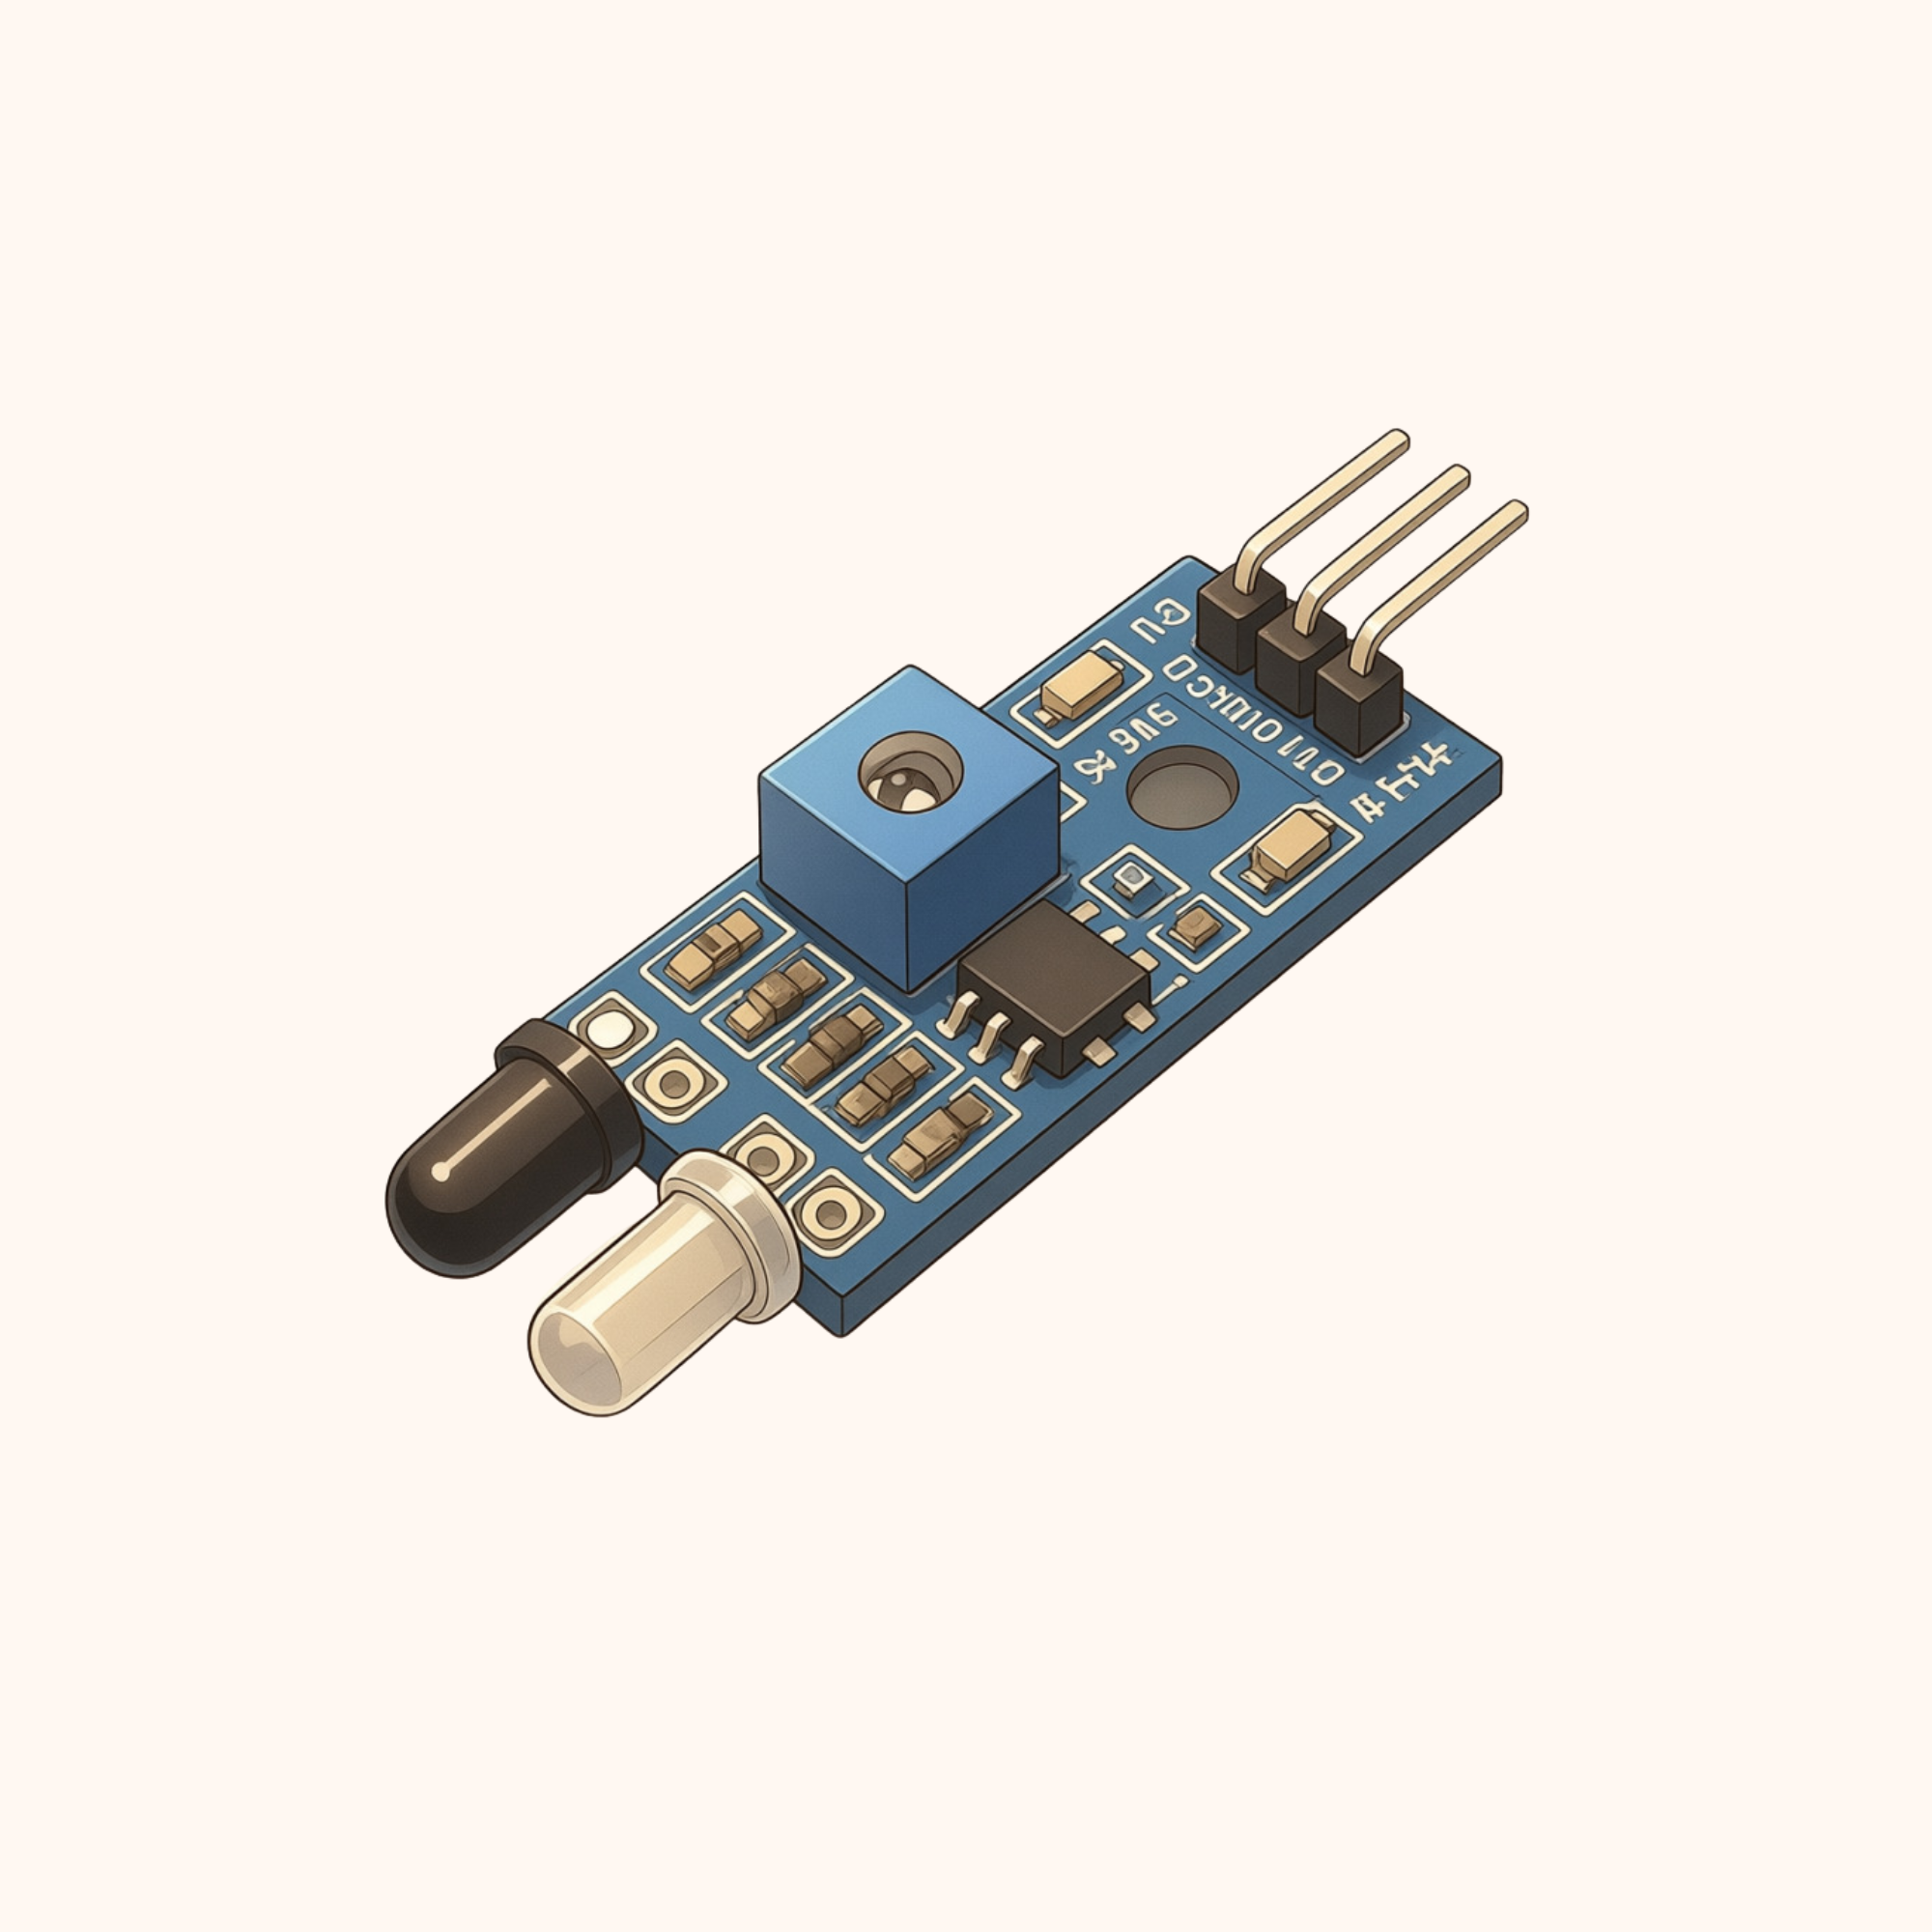 IR Sensor | ×2 | In stock | $1.18 | |
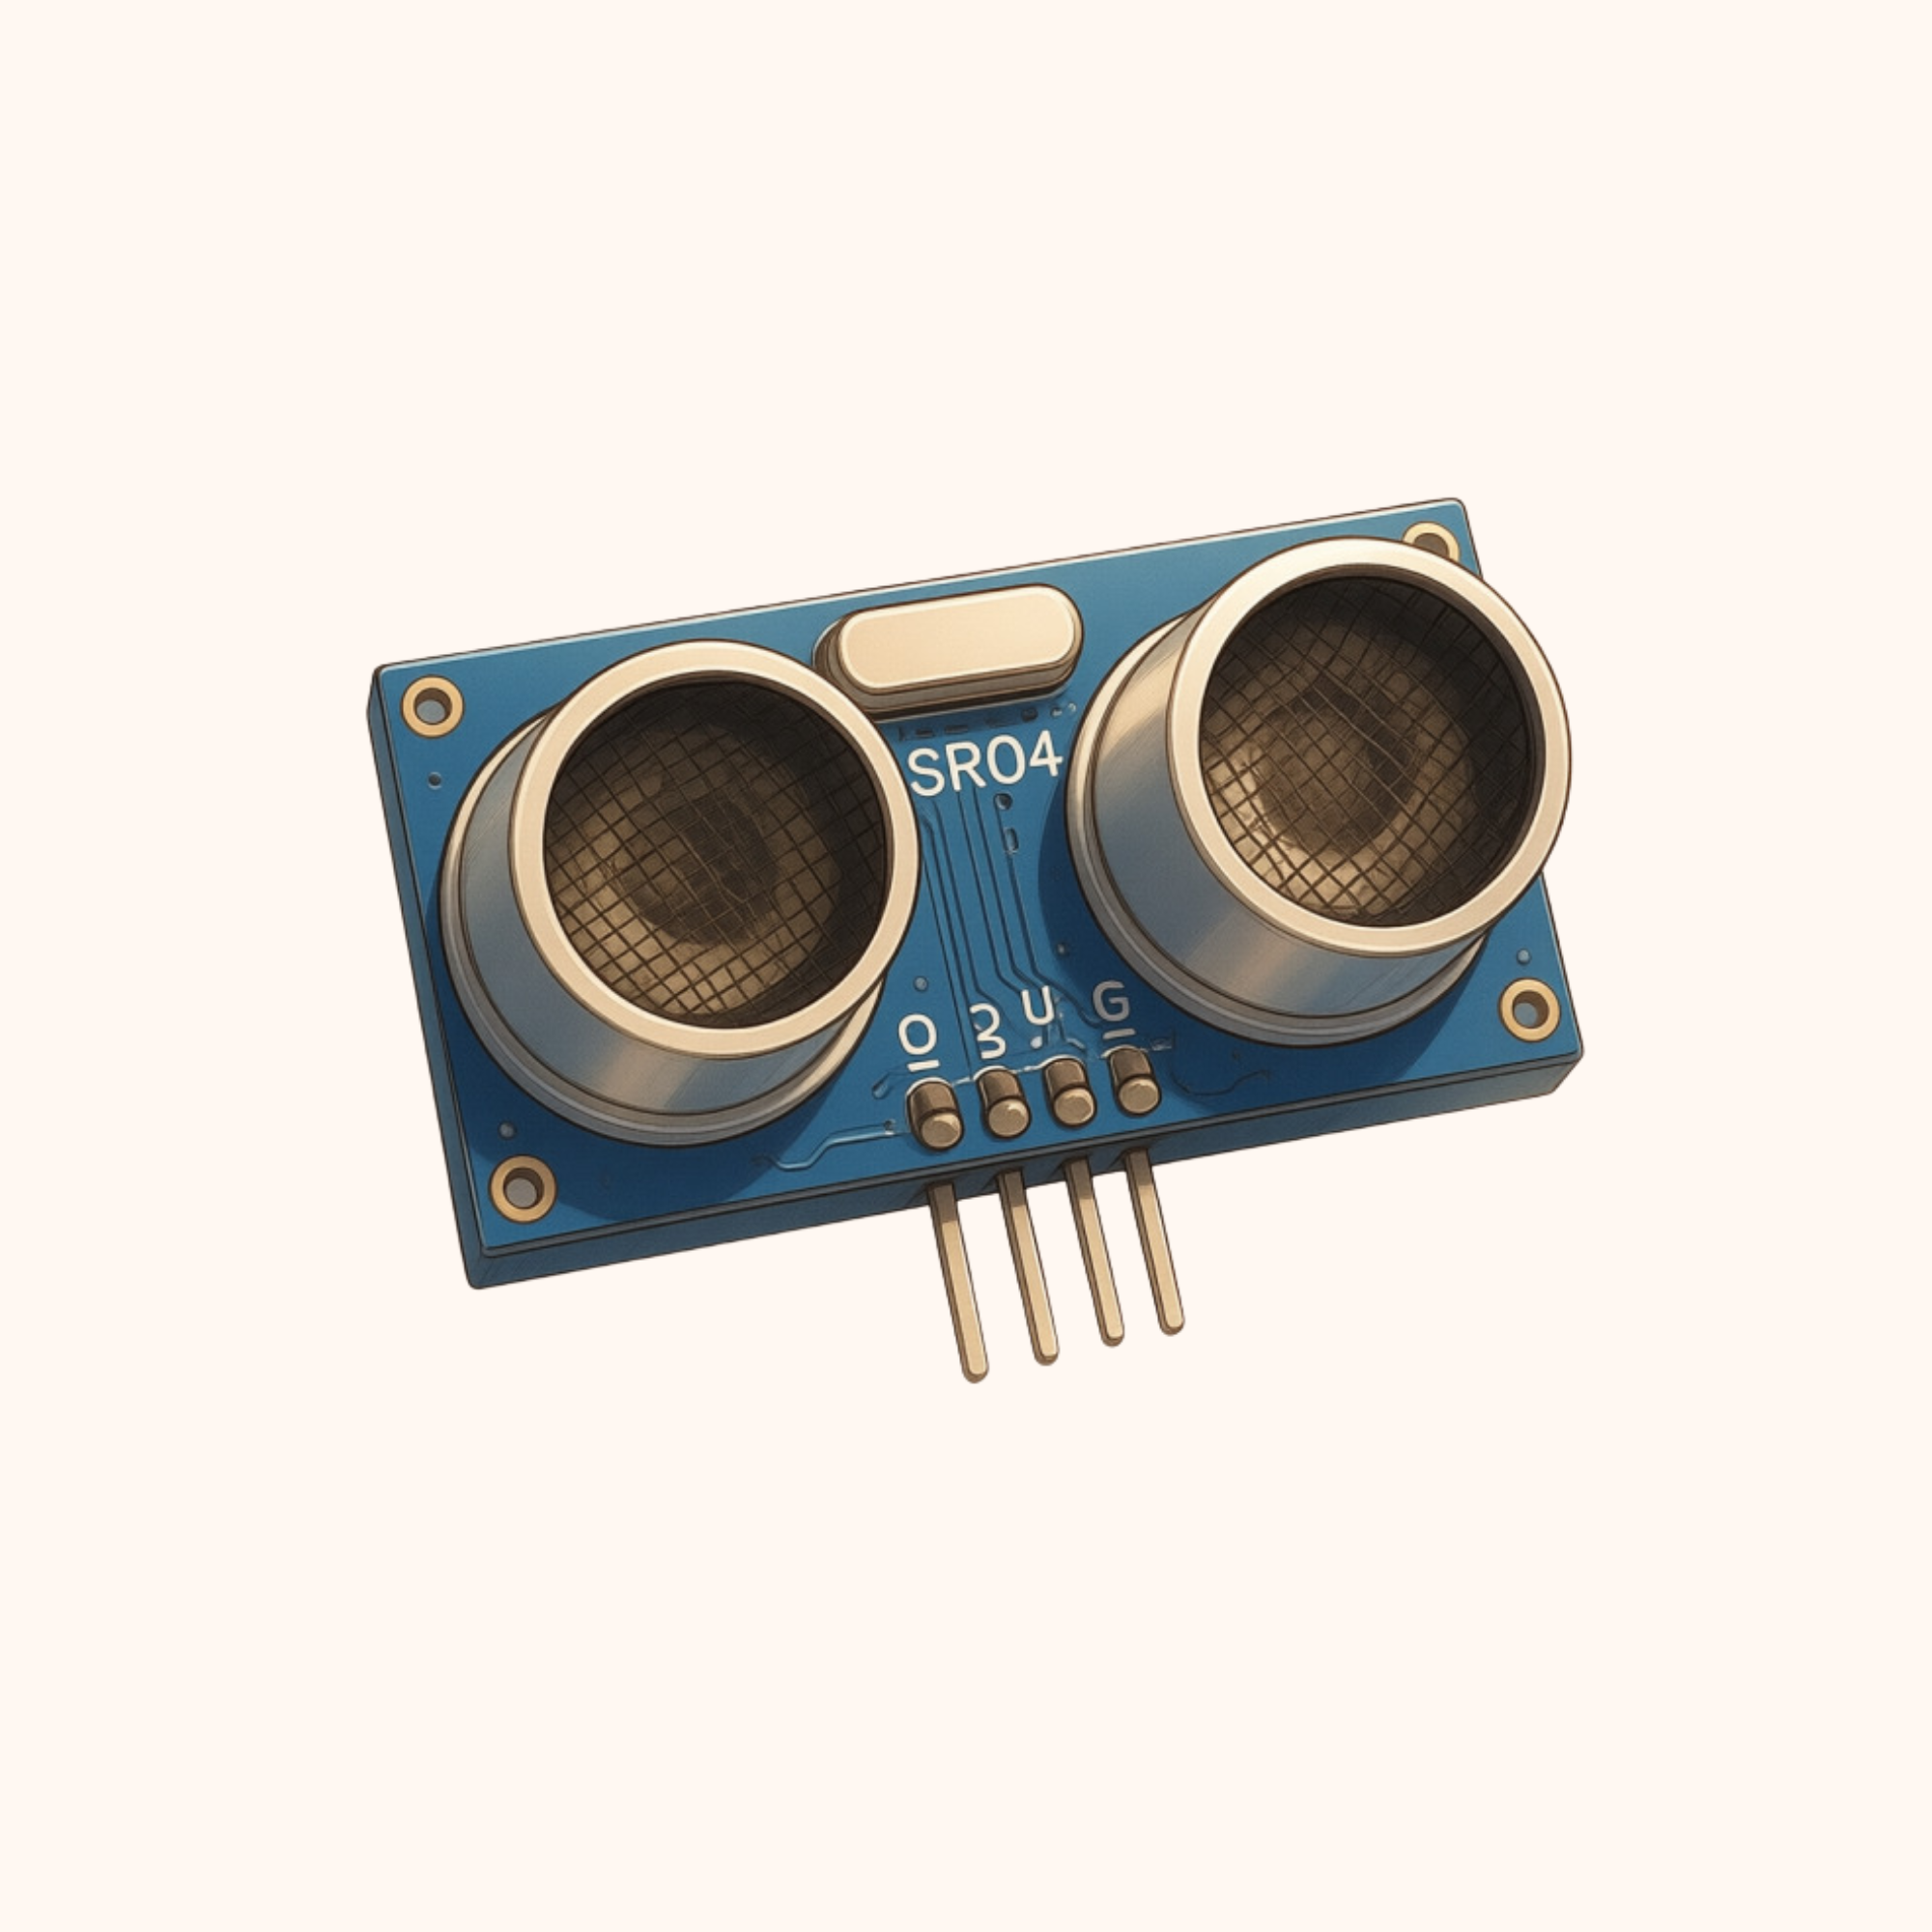 HC-SR04 Ultrasonic Sensor | ×1 | In stock | $1.19 | |
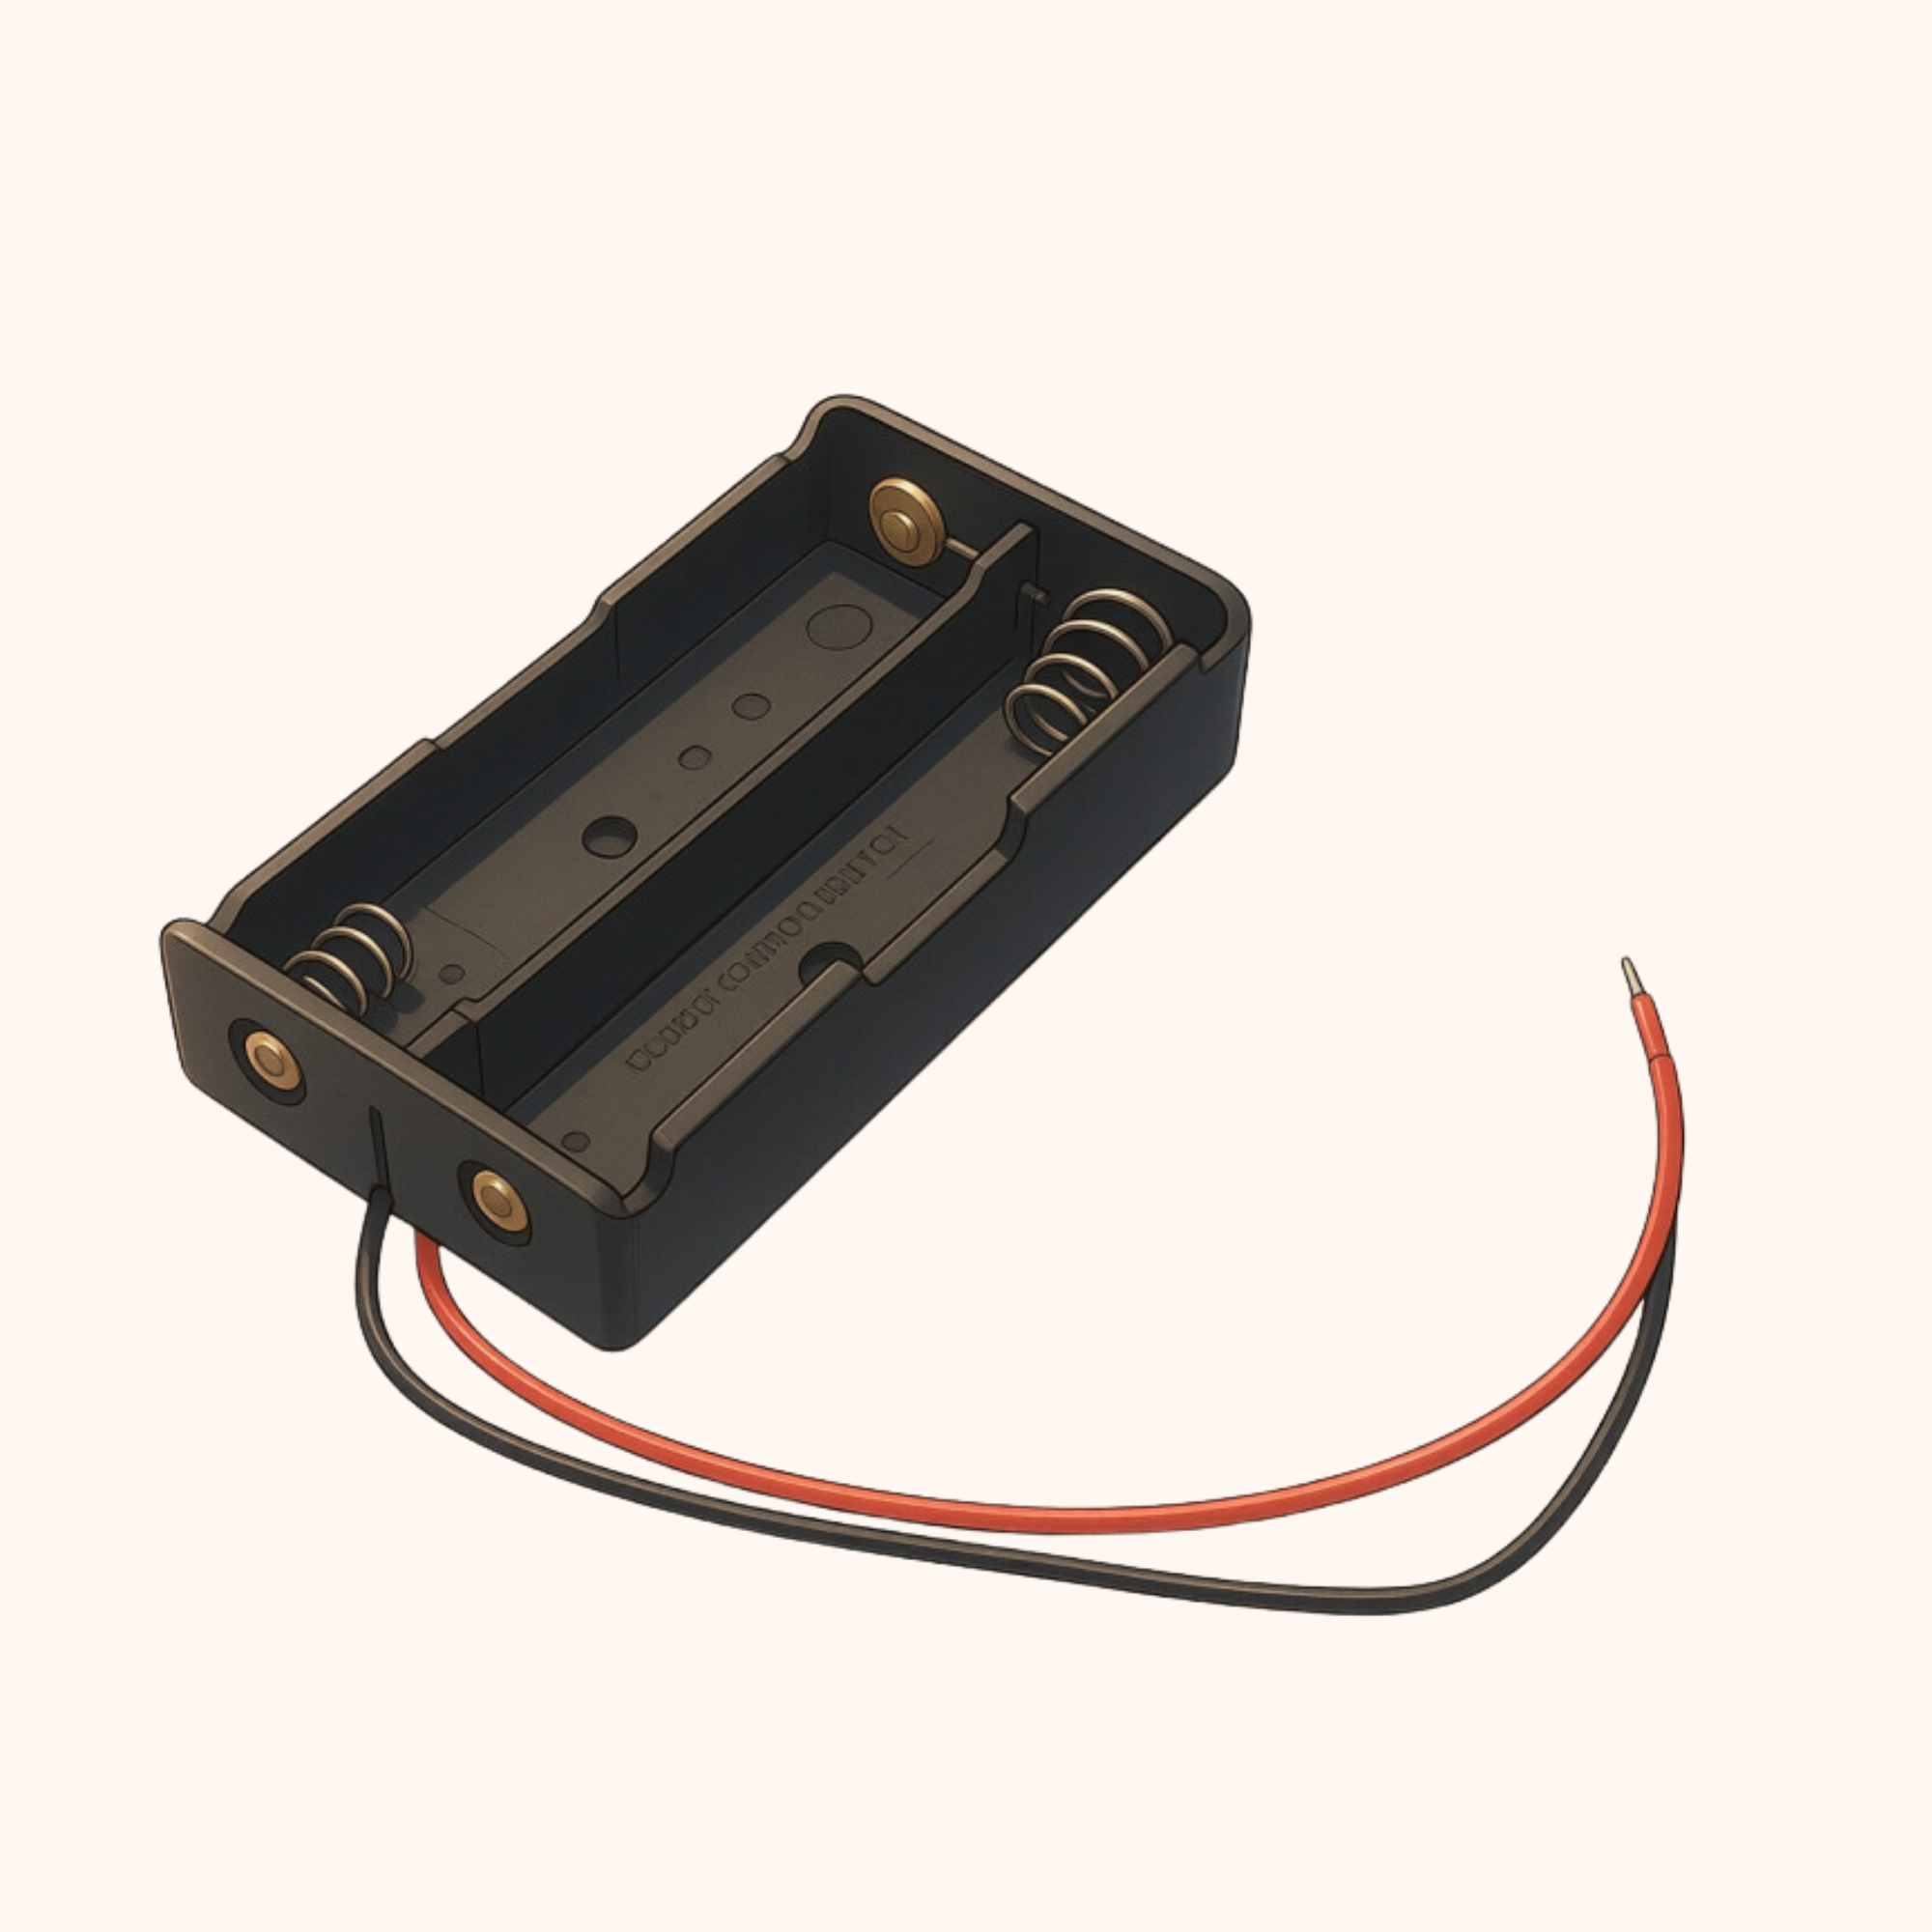 2S 3.7V 18650 Battery Holder | ×1 | In stock | $0.59 | |
| Mini Sumo Metal Chassis | ×1 | In stock | $7.89 | |
| Jumper Wire Set (120 pcs) | ×1 | In stock | $2.99 | |
| Bought one by one | $26.46 | |||
All of these come in Robo Sumo Kit.
Circuit & connections
The full wiring diagram and pin-by-pin connections.
Code
The complete, tested sketch (5 lines), ready to upload.
Step-by-step instructions
Troubleshooting
Fixes for the problems makers hit most often on this build.